Virtual Reality-Based Digital Shadow of Quadruped Locomotive System
Indraprastha Institute of Information Technology Delhi
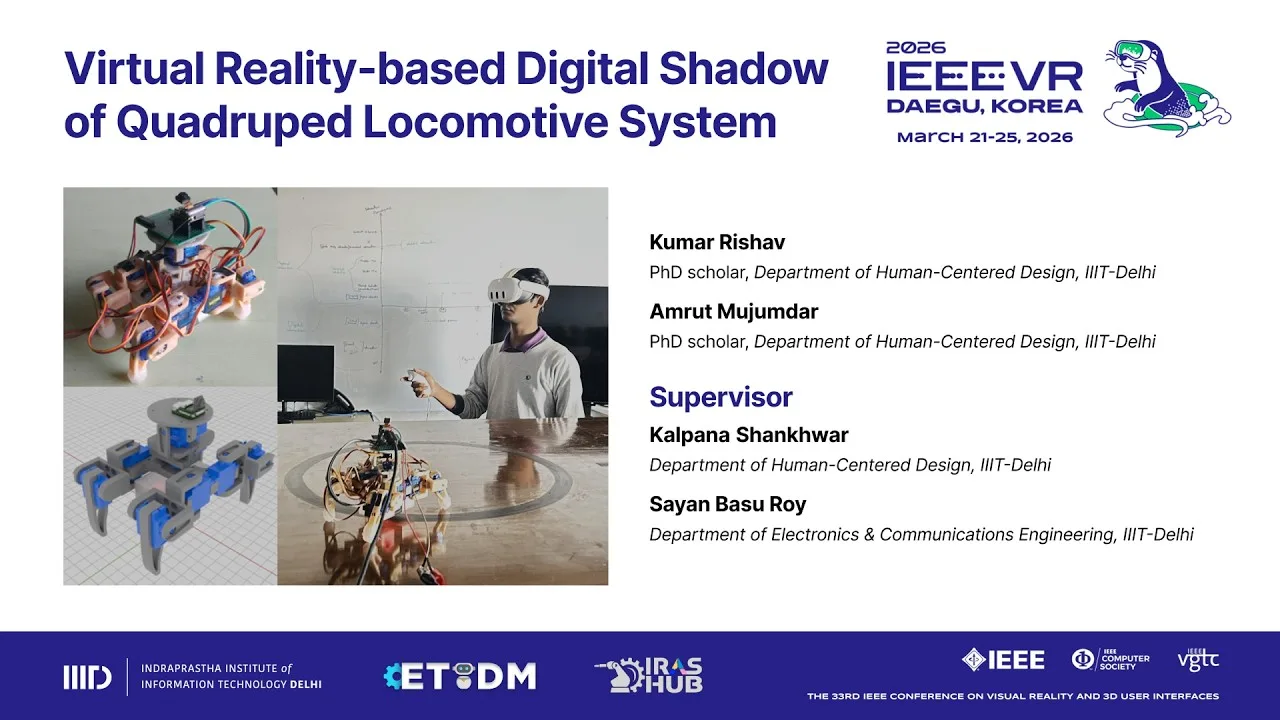
Abstract
Quadruped robots over years have gained significant application due to their advance terrain adaptability and tenet stability compared to wheeled platforms, nonetheless, the locomotion remains one of the most challenging problems in legged robotics over multi-joint coordination, operating in unpredictable environments, and dynamic stability constraints. We propose a low cost open-source quadruped designed to track the head orientation of an operator wearing a virtual reality (VR) headset, while also utilizing joystick commands for locomotion control with the integration of digital shadow to achieve stable locomotion by synchronized digital models of the physical entity for teleoperation applications.
Publication
2026 IEEE Conference on Virtual Reality and 3D User Interfaces Abstracts and Workshops (VRW)
- Date
- Pages
- 1295–1296
BibTeX
@inproceedings{rishav2026digitalshadow,
  title     = {Virtual Reality-Based Digital Shadow of Quadruped Locomotive System},
  author    = {Rishav, Kumar and Mujumdar, Amrut and Shankhwar, Kalpana and Roy, Sayan Basu},
  booktitle = {2026 IEEE Conference on Virtual Reality and 3D User Interfaces Abstracts and Workshops (VRW)},
  year      = {2026},
  month     = mar,
  pages     = {1295--1296},
  publisher = {IEEE},
  doi       = {10.1109/VRW70859.2026.00322},
  url       = {https://doi.org/10.1109/VRW70859.2026.00322}
}